Autonomy & perception for physical AI

Robots navigate
where infrastructures
fail

We enable autonomous machines to keep working in unstructured, degraded and contested environments.

See it work

Physical AI requires robust autonomy for robots to work in the real world, not just in ideal conditions.

Today's robots rely heavily on GPS, VIO and SLAM-based navigation, which fail in unstructured, cluttered, degraded or contested environments. We're building the next generation of autonomy and perception systems by combining AI-driven sensor fusion, edge processing and robotics control.

Our platform integrates novel radar, computer vision, edge processing and motion control technologies to enable robust, all-environment autonomy and perception systems across robotics, industrial operations and defense.

Into the unstructured.
No GPS. No map.

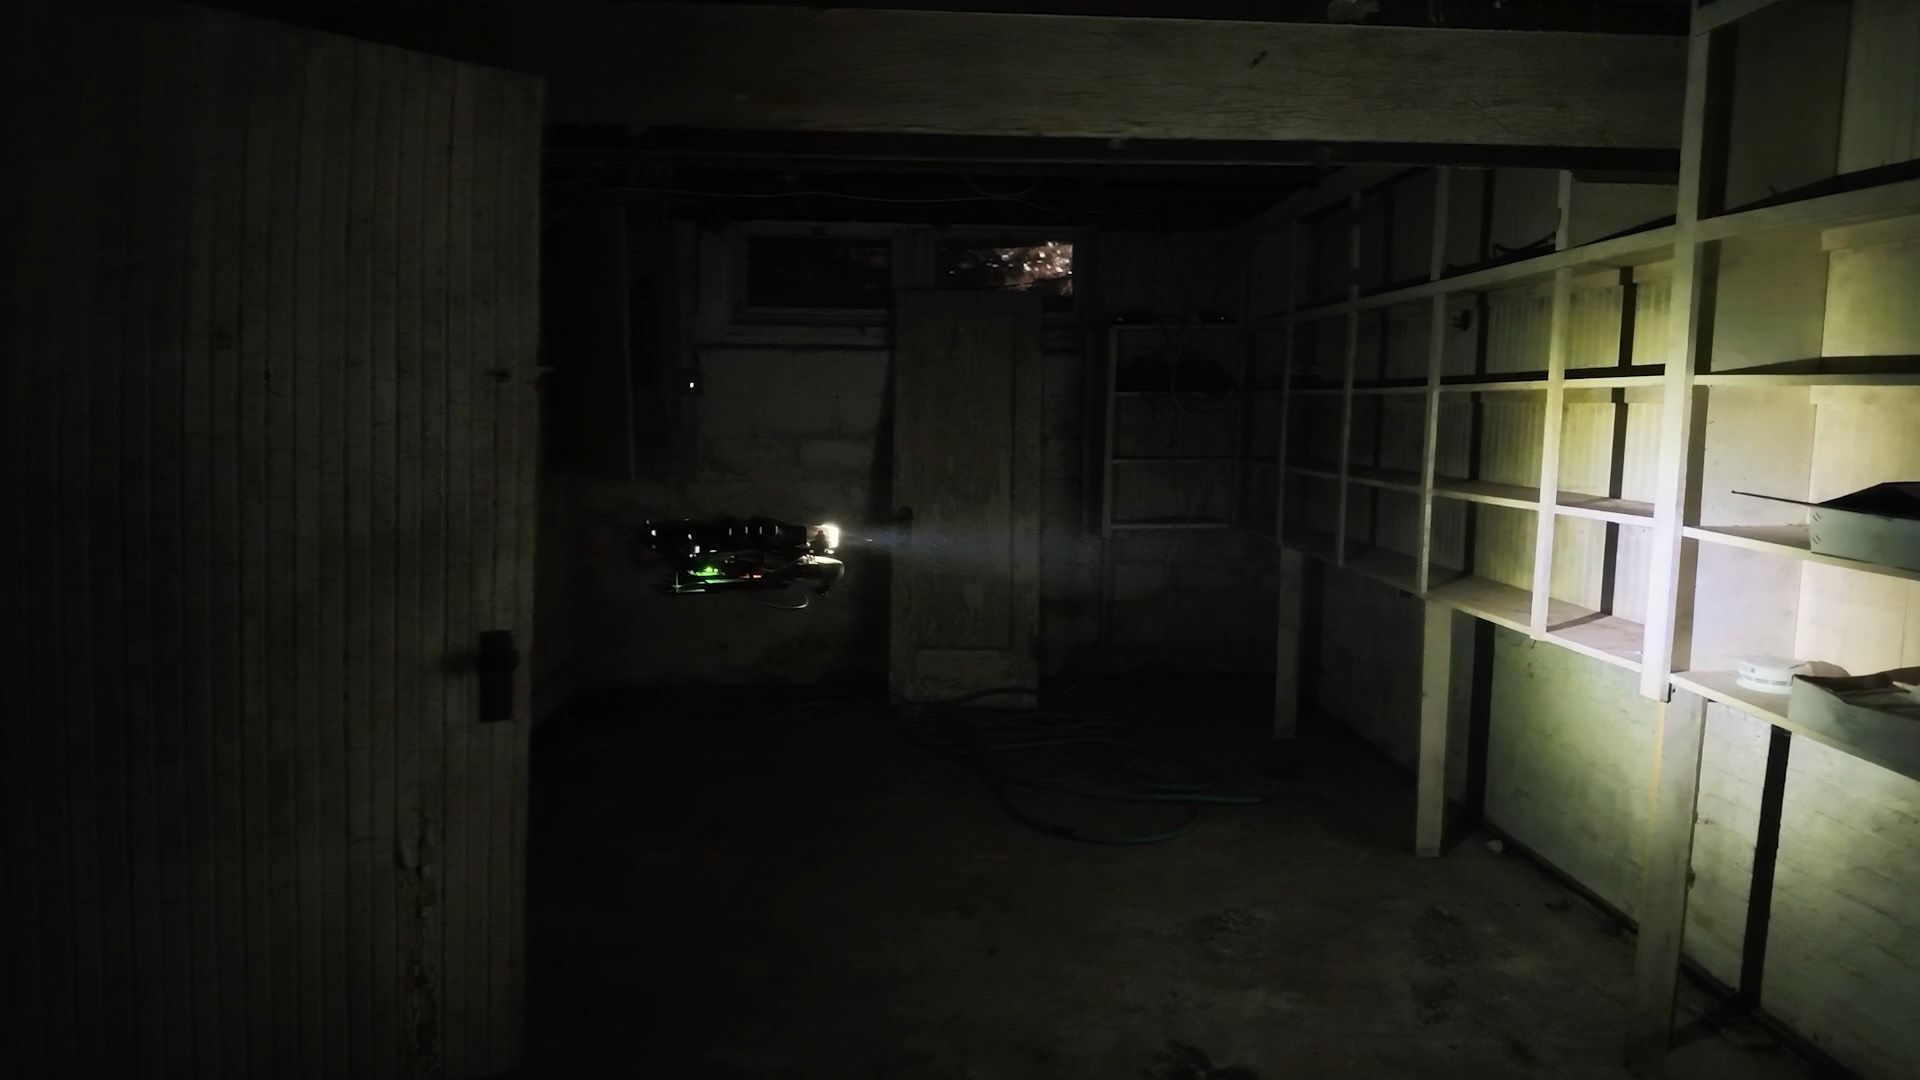
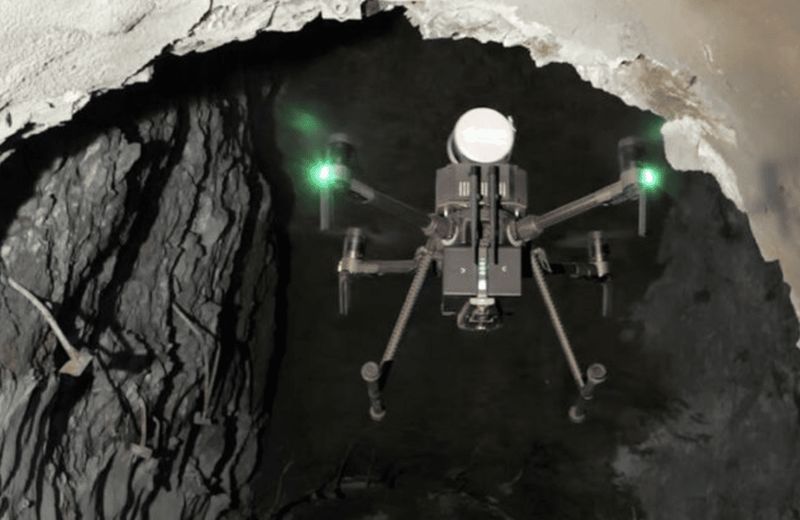
A pitch-black basement, with no GPS and no prior map of the space. Lit only by its own light, our drone perceived every obstacle around it in real time.

Our drone flying through a dark basement, lit only by its own light
Flight test in a dark basement, lit only by the drone's own light.

One perception stack for every environment.

A full-stack platform that combines advanced radio sensing, AI-driven perception and autonomy software, so systems operate reliably in complex, real-world environments where traditional sensors fail.

RF FRONT END RF FRONT END RF FRONT END RF FRONT END SMOKE · FOG · DUST TARGET
Hardware

Sub-terahertz radar

High-resolution sub-THz radar that operates in smoke, fog, dust and darkness, where cameras and LiDAR fail.

It delivers high range and spatial resolution in a compact, low-SWaP-C package built for industrial, robotics and defense environments.
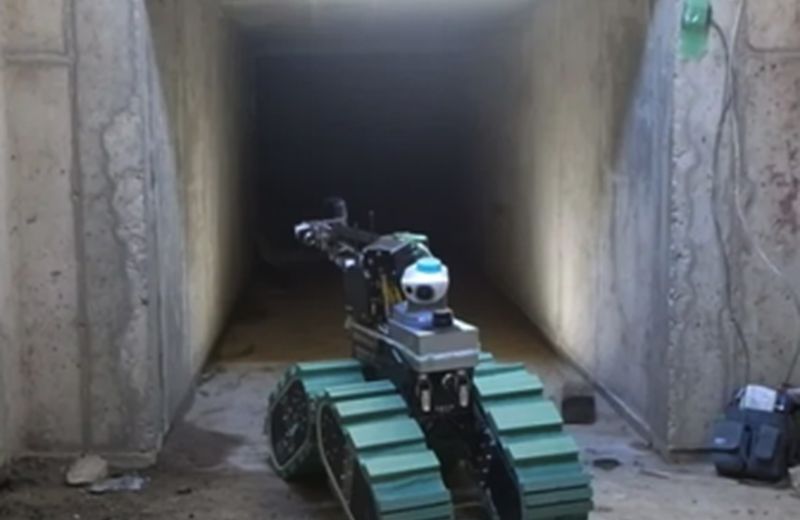
START GOAL GNSSDENIED LINKLOST PRIOR MAPNONE NAVONBOARD
Software

Open Loop Autonomy

Our autonomy framework navigates, tracks and completes missions using onboard sensing and compute alone: no GPS, no pre-built maps, no continuous communication.

Because it is observation-centric, it keeps working in GPS-denied and contested environments and holds the mission through communication loss. It reduces the need for constant human control while still supporting supervision, and deploys as a software upgrade to existing systems.

RADAR CAMERA LOW VISIBILITY MULTI-MODAL FUSION SCENE UNDERSTANDING NAVIGATION PATH PERSON VEHICLE
Machine learning

Sensor fusion and perception

Machine learning turns raw radar and camera data into a real-time understanding of the environment, more robust than any single sensor alone.

Edge-optimized models run object detection and tracking with low latency, and keep perception accurate when visibility drops.

EDGE COMPUTE JETSON-CLASS OPEN LOOP AUTONOMY UAV GROUND ROBOT AMR INTEGRATES WITH EXISTING STACKS PILOTFLEET
Deployment

Built to integrate

The platform runs in real time on edge devices such as NVIDIA Jetson and integrates with existing robotics and autonomy stacks.

Deploy it as a module or a full system, add capability through software upgrades to Open Loop Autonomy, and scale from a pilot to a fleet-wide rollout.

In the field

From perception to safe flight.

A real flight, replayed from the drone's own log. It spots the obstacles around it, marks a safety zone around each one, and keeps planning a clear path through.

01 ONBOARD CAMERA DEPTH ENHANCED DEPTH
02 LOCAL AWARENESS · 3D
SAFETY ZONE PLANNED PATH
DRAG TO ORBIT
00.0 / 23.0 s
OBSTACLES IN VIEW
GROUND SPEED–M/S
RELATIVE HEIGHT–M
NEAREST OBSTACLE–M
OBSTACLE POINTS–TRACKED
SENSE

Sees its surroundings in real time, onboard.

UNDERSTAND

Picks out the obstacles that matter.

PROTECT

Marks a safety zone around every one.

PLAN

Continuously re-plans a clear path.

NEXT

Sub-THz radar, so it keeps working when the camera can't see.

Recorded flight, replayed from the drone's log.

Built for the places
robots usually fail.

Our autonomy stack is plug-and-play and easily customizable for a wide range of industries operating in complex environmental conditions.

What partners say.

“Exciting to integrate Open Loop Autonomy with our UAS platforms.”
Antonio FelizianiOperator, RPAS Pilot, Technical Manager, APR Italia
“Aligns perfectly with our objectives.”
Mark LewandowskiDirector, Robotics Innovation, P&G
“Overcomes the limitations of how our AMRs perceive and navigate their environment with LiDAR sensors.”
You ChenBoard Chairman, Jaten
“Immense potential and aligns with our vision for the future of autonomous robotics.”
Juan WeeCEO, Kudan USA

Built by pioneering engineers and industry experts.

Our core team brings deep knowledge in advanced sensor systems, with more than 10 years at IBM Research, 100+ publications and 10+ patents, and in agile visual autonomy supported by DARPA and DEVCOM ARL: foundation-model perception, reactive mapless navigation, GPS-denied object-centric autonomy, and high-speed target search and tracking.

Team

Dr. Kevin Gu
Dr. Kevin GuCEO & Founder
Our robot guru
Our robot guruTechnical Lead
Maxwell Jin
Maxwell JinRobotics EngineerLinkedIn ↗
Tarunkumar Palanivelan
Tarunkumar PalanivelanRobotics EngineerLinkedIn ↗

Executive advisors

Marc Viggiano
Marc ViggianoCEO and Founder, Niteopark

More than 35 years designing advanced sensor and communication systems, including radar and air traffic control. Former head of Saab’s Traffic Management business and CEO of Saab Sensis, he helped grow Sensis from a startup to a 700-person company.

Ken Stewart
Ken StewartCEO and Founder, Stewart Advisory Partners

Former President and CEO of NUAIR and CEO of AiRXOS, a GE Aviation company, with more than 25 years leading aviation, emerging technology and business growth, and an active voice in the commercial drone industry.

Ken Kaminski
Ken KaminskiAerospace and Defense

Retired aerospace executive who served as Program Director of Airborne Radar at Lockheed Martin, Director of the Electronic Systems Laboratory at Georgia Tech, and General Manager of Air Traffic Management at Saab AB.

Karen Roth
Karen RothFounder, RothSalluzzo, LLC

Department of Defense and technology leader in cyber, artificial intelligence, digital and systems engineering, with senior leadership roles at the Air Force Research Laboratory across a $1.5 billion research portfolio.

R&D collaborators

Dr. Wooram Lee
Dr. Wooram LeeR&D CollaboratorPenn State, Associate Professor
Dr. Mark Rodwell
Dr. Mark RodwellR&D CollaboratorUCSB, Professor
Dr. Michael Chung-Tse Wu
Dr. Michael Chung-Tse WuR&D CollaboratorRutgers / National Taiwan University
Diana Strickland, Ph.D.
Diana Strickland, Ph.D.R&D CollaboratorAdvanced Science Research Center, CUNY

News and support.

Grants, awards and programs backing our work. Read more in Speeding up with Astrabeam (NYC Innovation Hotspot) and about our collaboration with CUNY ASRC.

  • DIU Fuse Accelerator, Fall 2026 Cohort

    Selected for the Fall 2026 cohort of the Fuse Ventures dual-use accelerator.

  • 2026 FuzeHub Manufacturing Grant

    Advanced multi-modal sensor fusion for heavy machinery functional safety.

  • Westchester Innovation Network

    Partnership to test our safety sensors on heavy machinery.

  • Genius NY, Round 10 Finalist

    Finalist of Genius NY, the world's leading robotics and drone accelerator.

  • NYSTAR IMG Grant Award

    Awarded a commitment letter for the NYSTAR IMG Grant.

  • NEMC Propel Operations Grant

    Startup awardee, for radar prototyping development.

  • NSF STTR Phase I Award

    A D-band, silicon-based, phased array radar front-end module for smart sensing applications.

  • NSF FuSe Grant

    Future of Semiconductors: heterogeneous module, array antenna and IC co-design for energy-efficient D-band wireless communications and radar.

  • NASA SBIR Phase I Award

    Ultra-low-loss millimeter-wave holographic antennas for CubeSat remote sensing.

  • NVIDIA Inception Program

    Startup member.

  • Plug and Play Semiconductor Accelerator

    Fall 2024 batch startup member.

  • Element 46 Accelerator

    Fall 2024 cohort startup member.

Put our autonomy in your robot.

Tell us about your platform and the conditions it struggles in, and we'll get back to you.

Email
info@astrabeam.com
Phone
(914) 222-1149
Office
520 White Plains Road, Suite 500
Tarrytown, NY 10591